
Know AI. See What’s Next.




Slide 1 of 5: 姜宇辉的AI分身:知识助手与“另一个自己”之间
Latest news
ERNIE 5.5 Flash Preview launches, showcasing long-horizon coding and creative work (opens in a new tab)
Baidu reports model architecture, API pricing, and game and animation demos, with weights planned for November 25. Media trials cover 3D scenes and science videos.
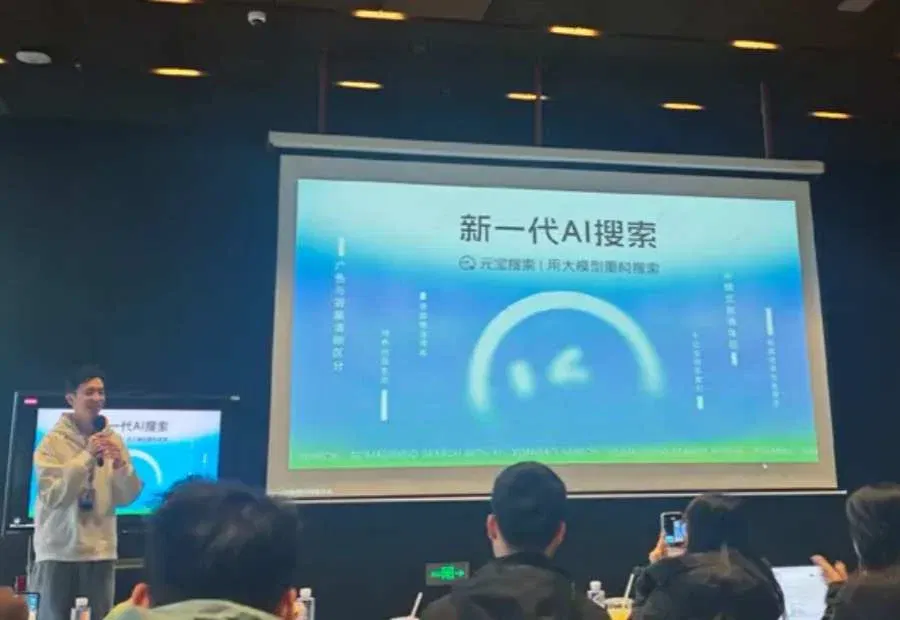
Tencent launches Yuanbao Search web app with WeChat accounts and AI summaries (opens in a new tab)
Zhidx tests the independent search entry point, authoritative sources, WeChat content, and structured cards, also noting limits in video freshness, link availability, and advertising observations.
Anthropic updates supported-region terms, clarifying entity control and usage restrictions (opens in a new tab)
The terms restrict users’ locations, entities’ incorporation or headquarters, and majority ownership or control. Their specific application depends on the terms and product documentation.
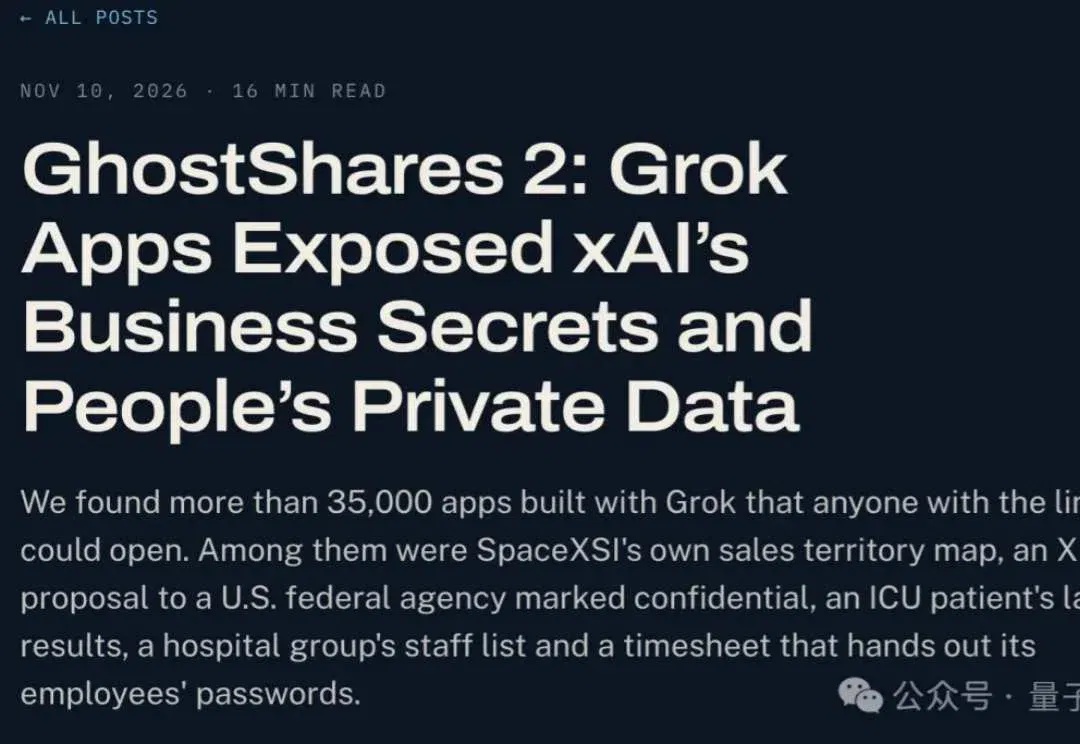
Claroc reports Grok Build access-control risks exposing internal data (opens in a new tab)
Researchers tested public app URLs, found many accessible without login and confirmed a permission flaw in a self-built app. Platform and researcher accounts of default sharing settings differ.
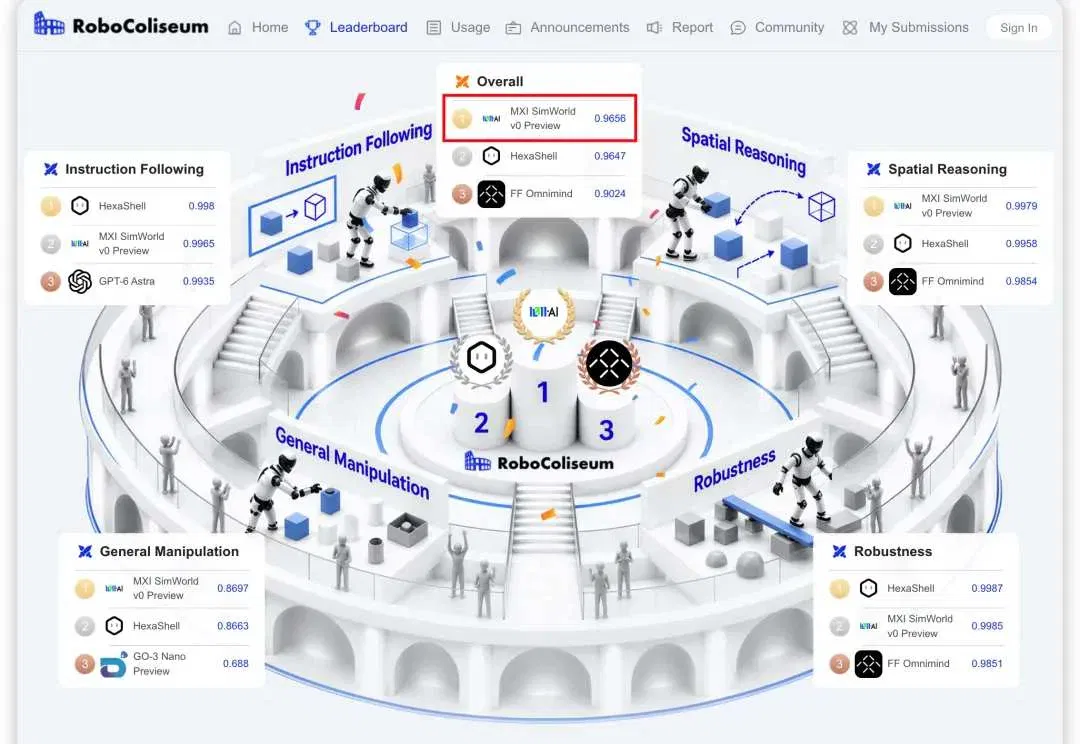
MXI-SimWorld tops RoboColiseum's weekly rankings and selects actions through simulation (opens in a new tab)
The team describes a system linking scene reconstruction, interaction calibration and parallel action rehearsals. The report gives November 11 rankings and outlines real-robot validation.
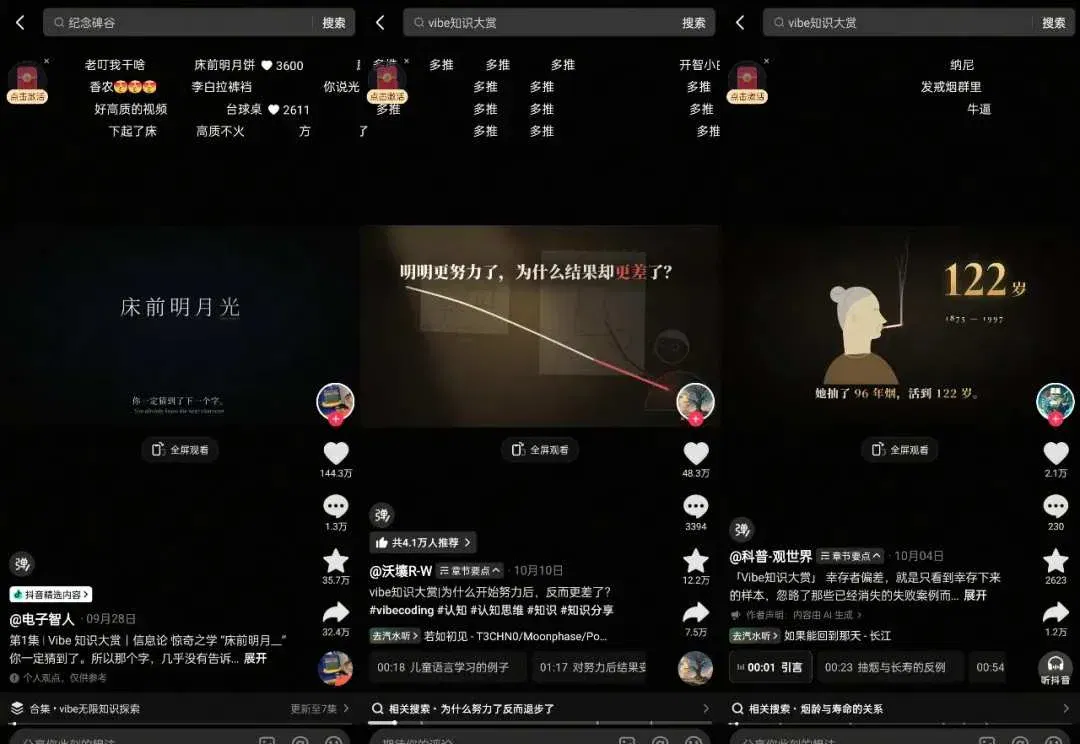
Jimeng launches Motion Studio: Synced tries making knowledge videos (opens in a new tab)
Synced tests code-driven animation with entropy, the laws of robotics, recursive self-improvement and Chinese character evolution, recording generation times, revisions and errors in specialist knowledge.
Tsinghua and Berkeley open-source uni-robot-agent to unify robot tool interfaces (opens in a new tab)
The framework connects models, simulation, and real robots through modular tools. The paper reports multi-model tests, differences in input conditions, and operating costs, and explores streamlined tools and asynchronous execution.
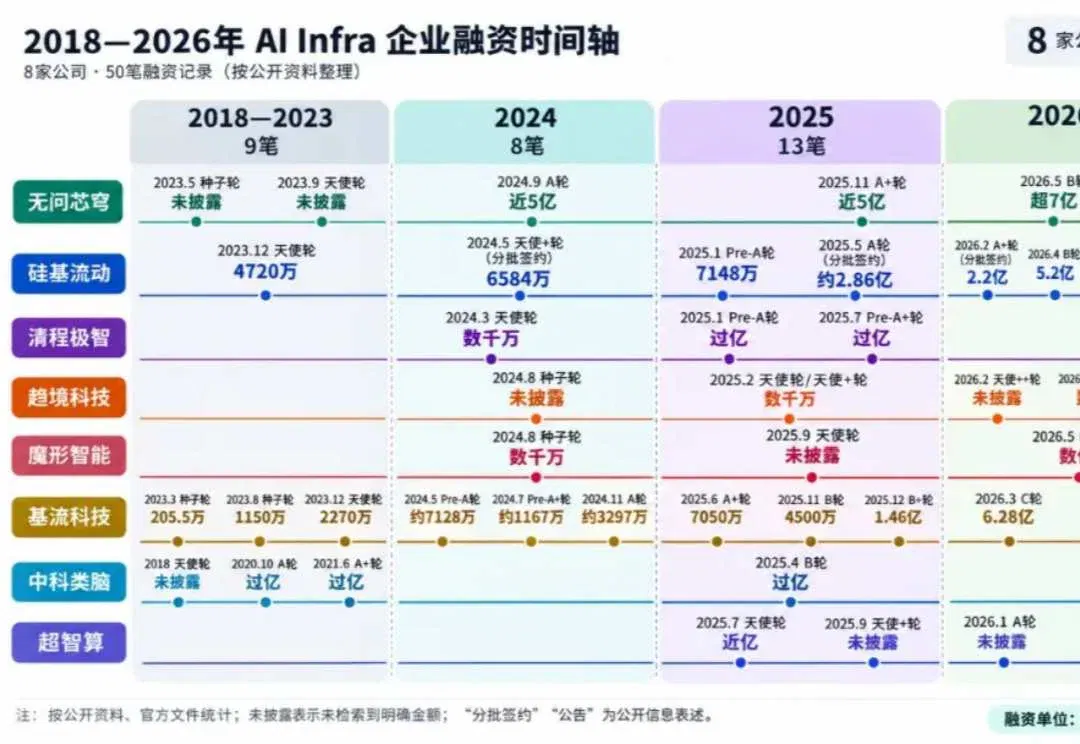
八家第三方 AI Infra 企业前十月完成20轮融资,商业前景仍有分歧 (opens in a new tab)
雷峰网梳理国内算力调度、部署及推理服务商的融资,并采访投资人,讨论资金集中、大厂替代风险和盈利压力。
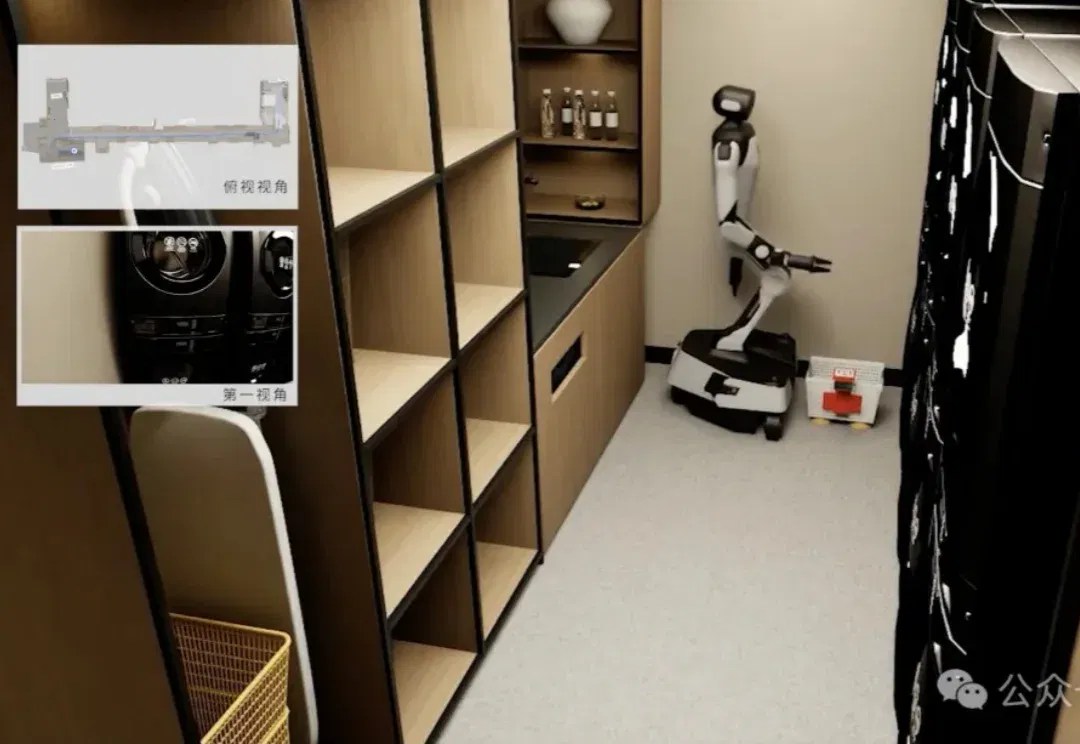
大晓机器人展示酒店洗衣方案,用双脑架构迭代操作技能 (opens in a new tab)
方案以世界模型支持预演、通用模型生成技能、端侧执行动作。团队披露取衣实验中的迭代耗时和残留率,完整业务效果仍待验证。
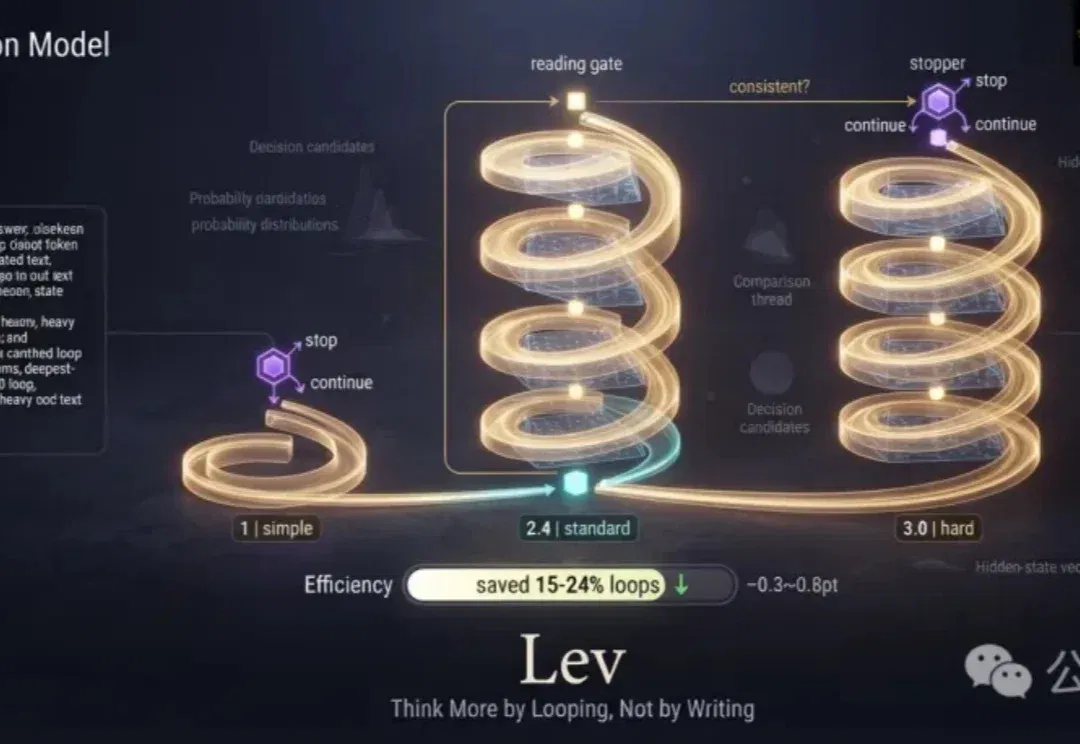
Lev 用循环计算按题分配推理深度,测试提前停止策略 (opens in a new tab)
研究团队在固定测试集上比较不同循环次数,并训练提前停止规则,以较少计算接近完整循环结果;可靠性仍取决于基础模型。
Claude 漏洞发现增加,公开修复记录与审核能力受关注 (opens in a new tab)
VulnCheck 追踪报告讨论候选漏洞与公开修复记录的差距。Anthropic 公布的审核和上游补丁数据采用不同口径,不能直接等同。
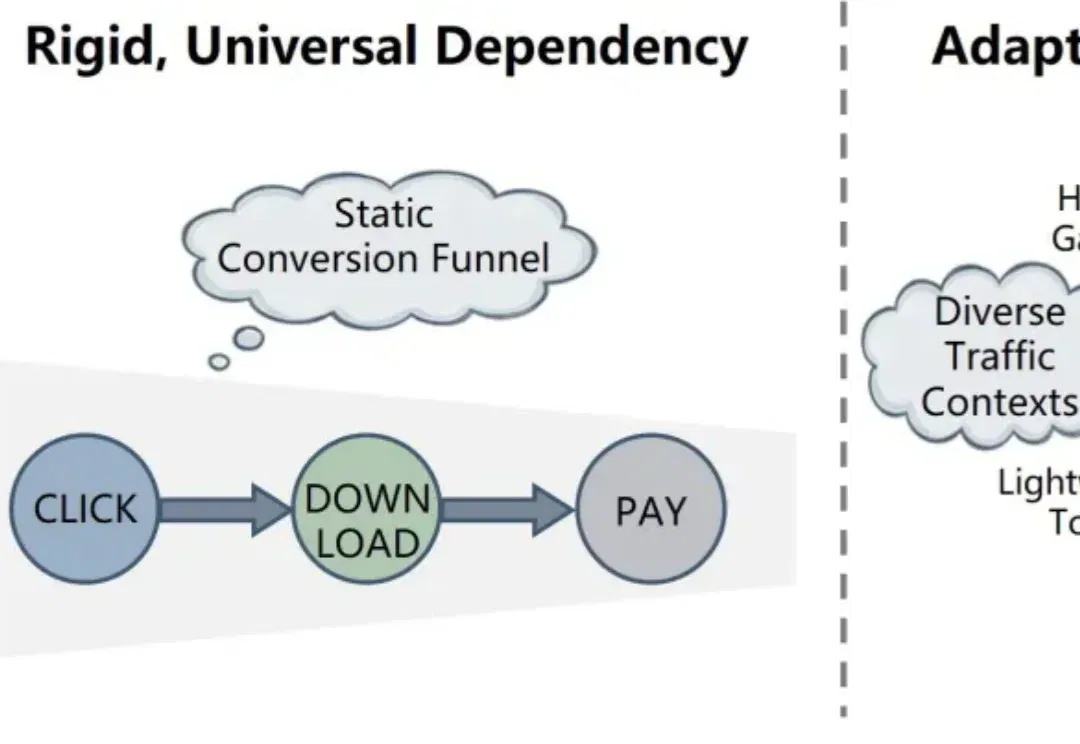
PTDG 为多任务推荐学习任务关系,论文报告线上转化收益 (opens in a new tab)
研究团队用低秩任务图和渐进稀疏掩码缓解多任务干扰,在公开及工业数据上测试,并披露两周线上 A/B 实验结果。
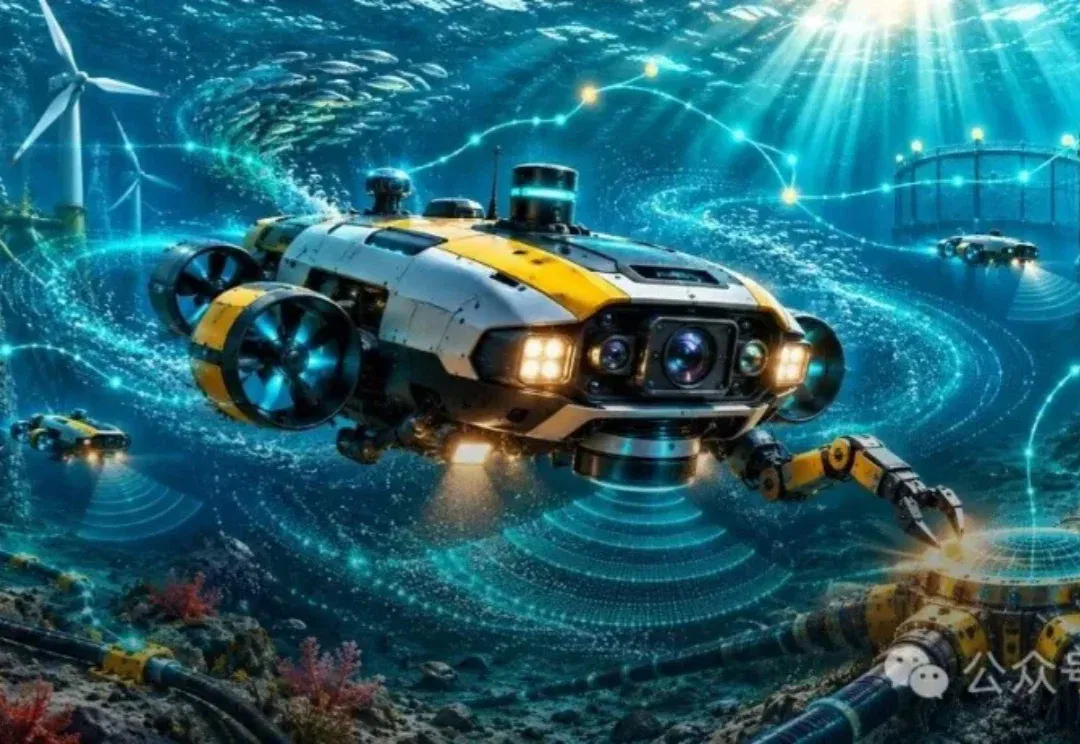
领渊智能获千万元种子轮融资,探索水下机器人软件 (opens in a new tab)
据新智元报道,领渊智能完成千万元级种子轮融资,计划以水下基础模型、任务规划和多机器人协作软件切入行业应用。
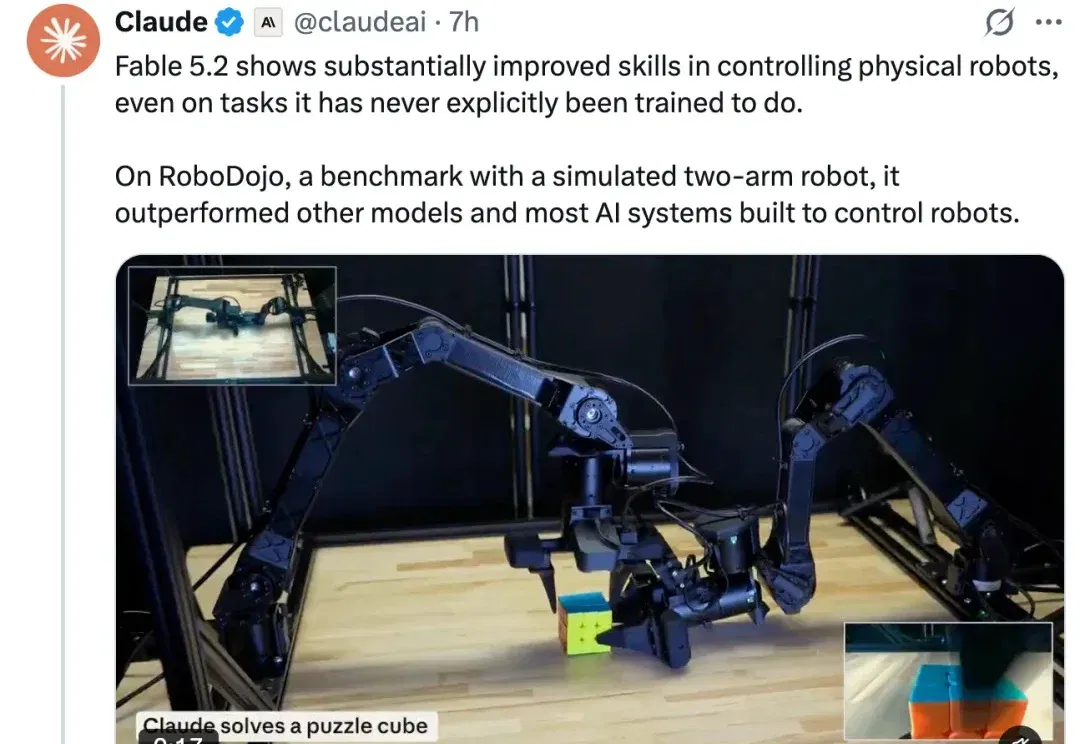
Q0-Preview 用空间计算与工具调用组织机器人操作 (opens in a new tab)
乾章智能介绍基于 Opus 5.5 的机器人智能体,利用像素定位、坐标计算和运动规划完成任务,并披露其仿真评测成绩与成本限制。
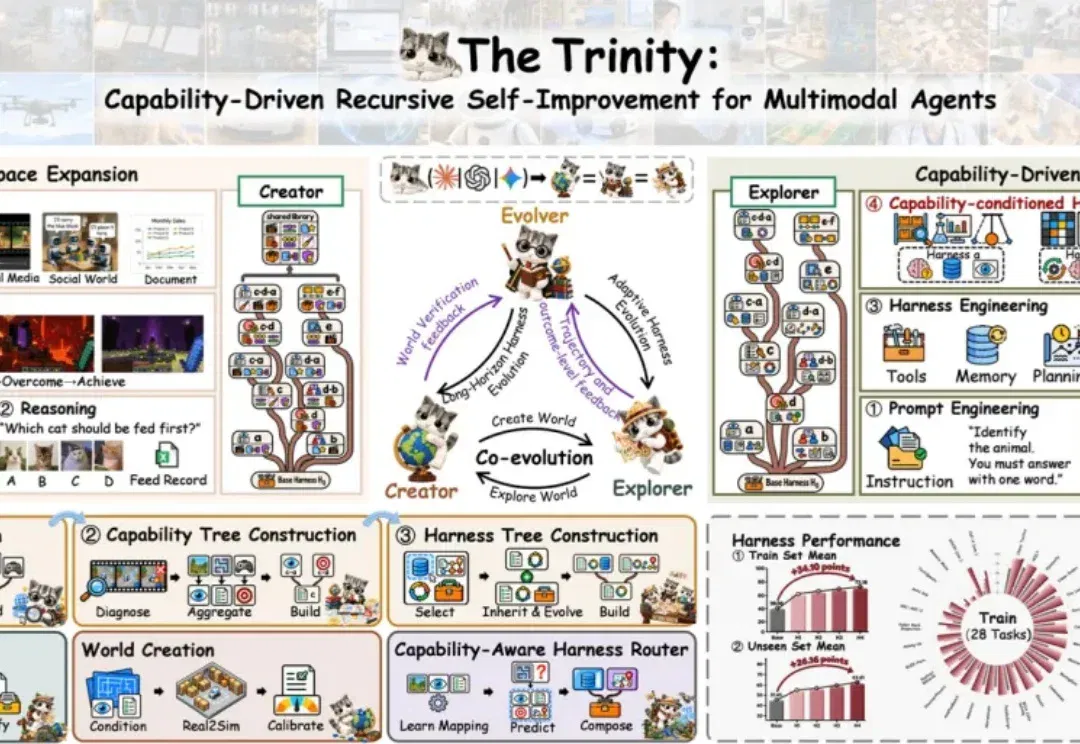
The Trinity 按能力组织智能体运行框架,测试跨任务迁移 (opens in a new tab)
团队让环境生成、探索和框架改进三个角色协作,在固定基座模型下迭代运行框架。论文报告四轮实验和两个真机任务的迁移结果。
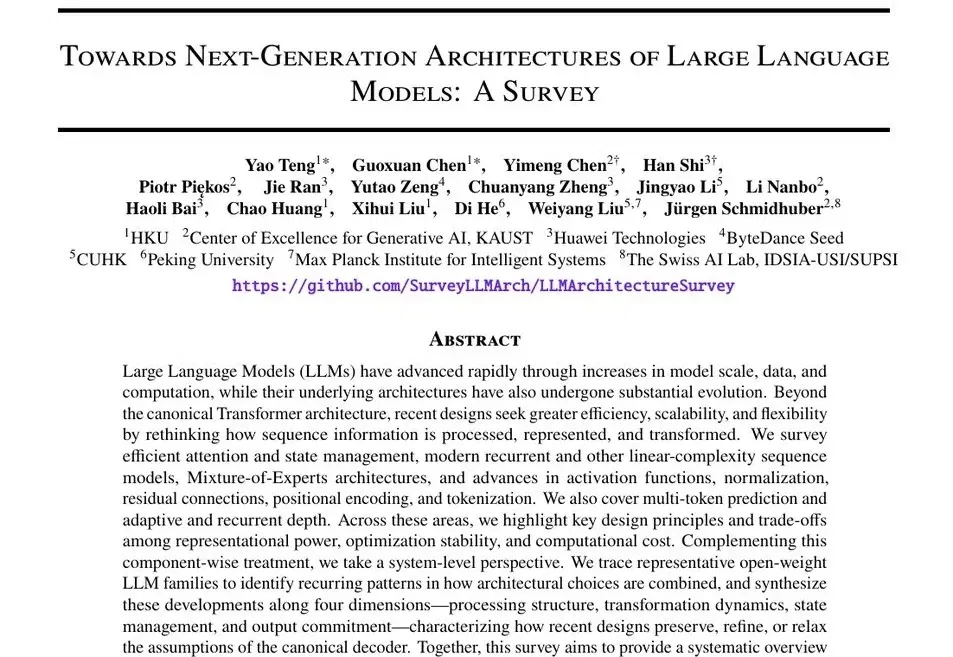
语言模型架构综述,从注意力与 MoE 到循环深度 (opens in a new tab)
多机构团队发布架构综述,梳理缓存压缩、线性模型、专家网络和生成计算分配,并讨论架构与底层系统的配合。
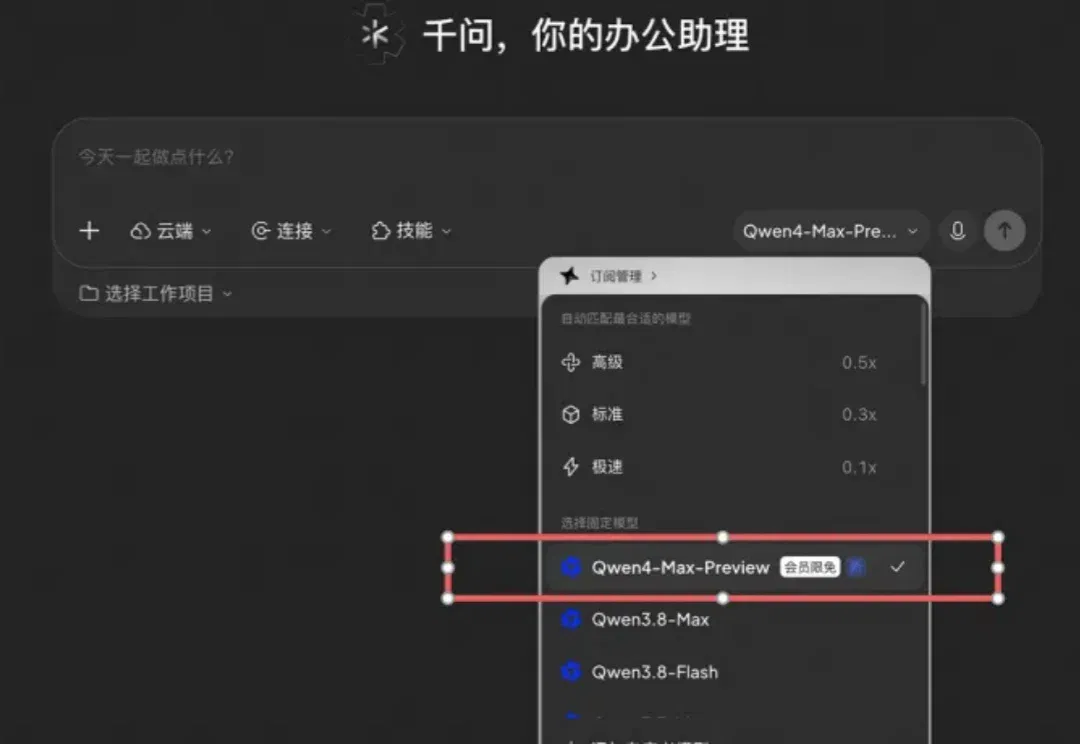
千问 Qwen4-Max 预览版体验,动画与交互表现怎样 (opens in a new tab)
智东西用动画、交互场景和 GIF 任务体验 Qwen4-Max 预览版,记录了生成耗时、控制细节与字幕错位等问题。
独立开发者 Jet 分享 Agent 运营实践,月度调用费用约 2500 美元 (opens in a new tab)
Jet 自述用多套 Agent 分担多个项目的维护与运营,并估计承担了原需多人处理的工作。文章也记录人工审核、业务回写和持续维护的要求。
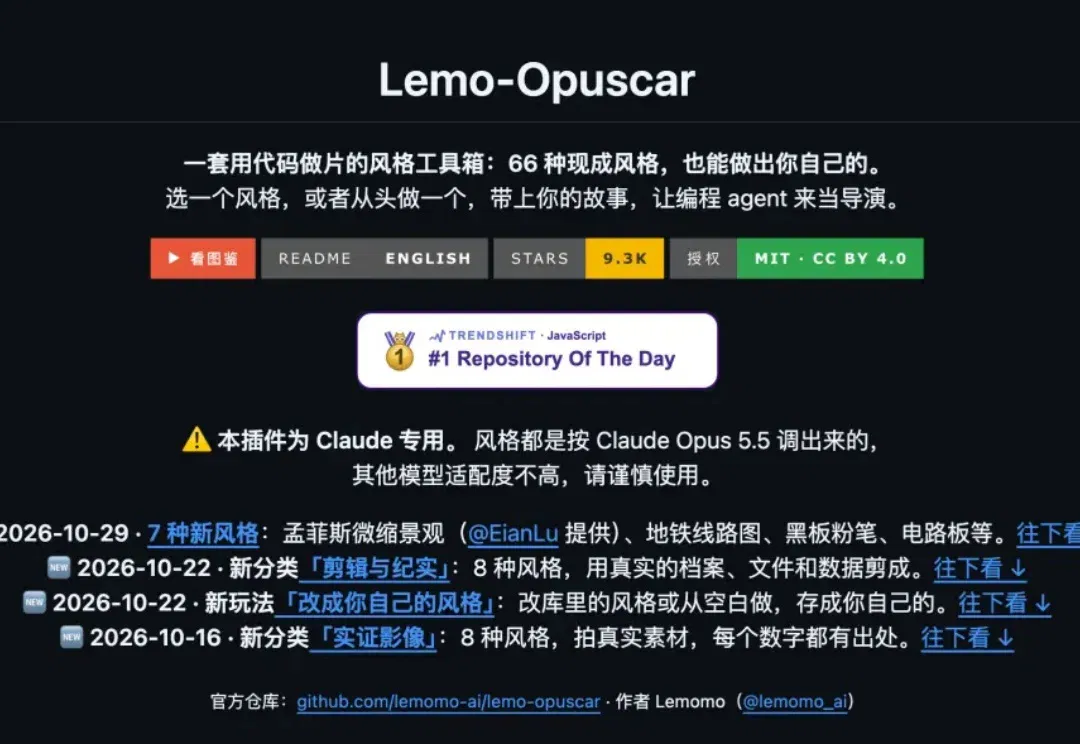
九个开源动画项目,从代码绘画到视频编排 (opens in a new tab)
文章整理九个制作动画、讲解短片和产品视频的项目,介绍风格模板、分镜、可修改工程及本地渲染环境。项目热度采用报道时点的数据。
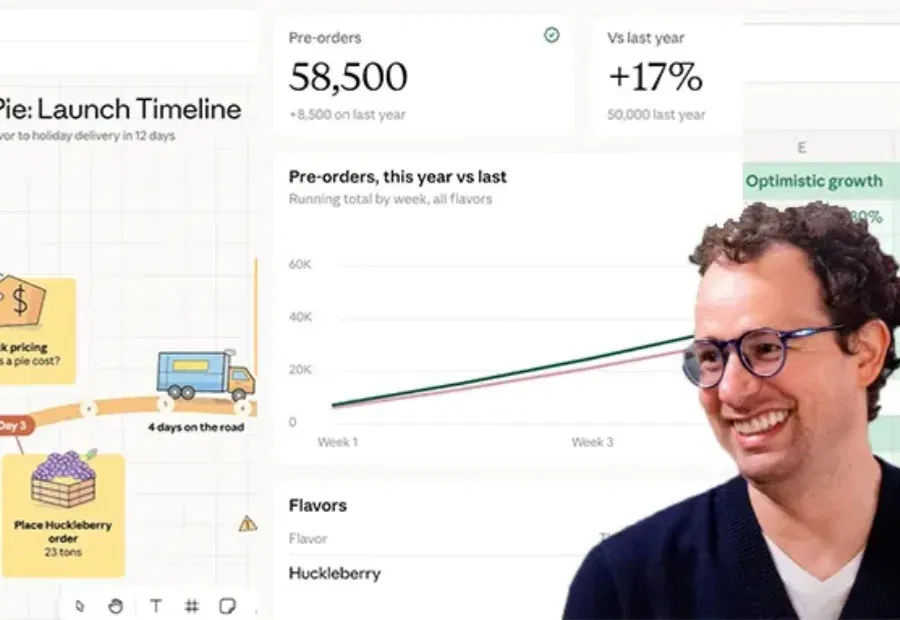
Claude 推出表格与白板工具,更新数据分析和应用连接 (opens in a new tab)
Anthropic 公布 Claude Sheets、Whiteboards 及 Data 更新,覆盖表格编辑、团队构思和数据解读。部分能力分批推出,连接器及账号条件各有不同。