Tsinghua and Berkeley open-source uni-robot-agent to unify robot tool interfaces (opens in a new tab)
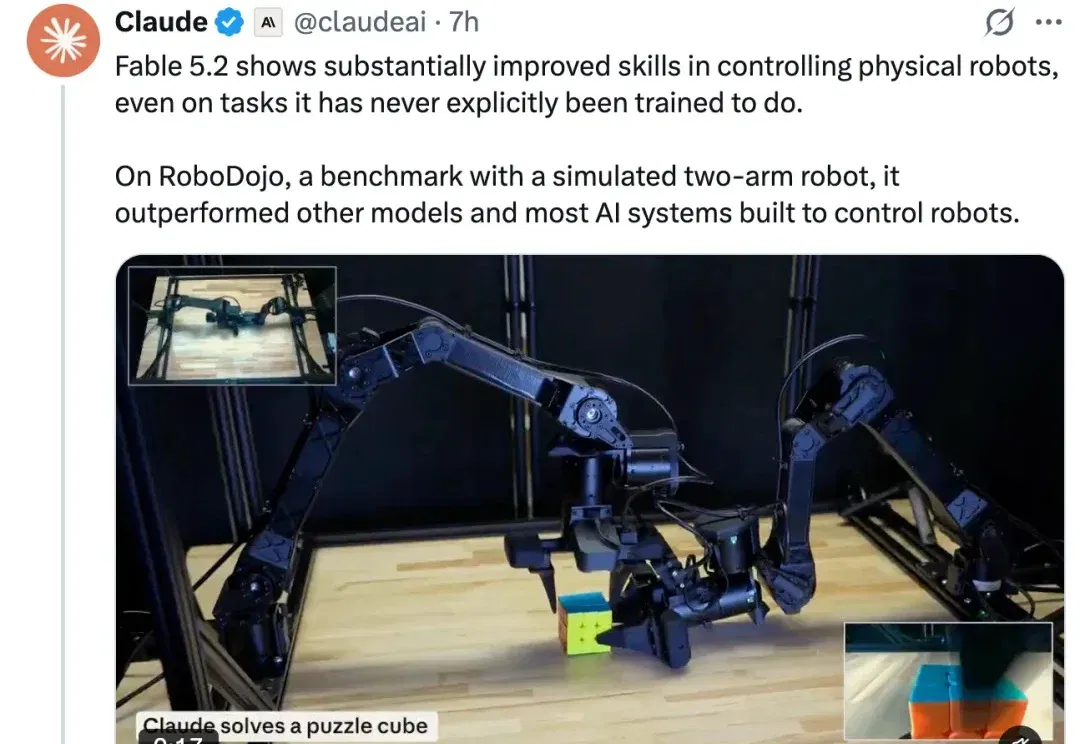
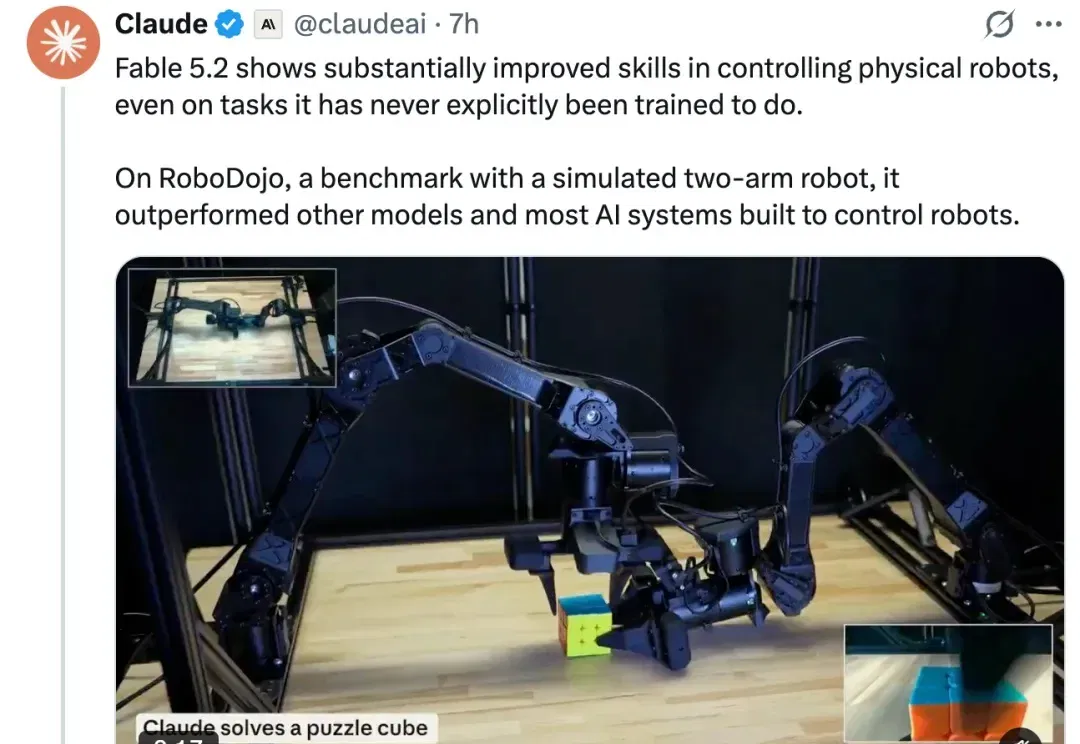
The framework connects models, simulation, and real robots through modular tools. The paper reports multi-model tests, differences in input conditions, and operating costs, and explores streamlined tools and asynchronous execution.